GUERRERO CASTELLANOS, JOSE FERMI
INGENIERÍA · Nivel 2
Desde 2008 es Professor en Benemérita Universidad Autónoma de Puebla
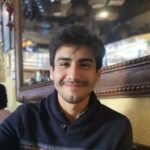
José Fermi Guerrero Castellanos was born in Poza Rica, Mexico. He received the “Licenciatura” degree in electronic science, Autonomous University...
José Fermi Guerrero Castellanos was born in Poza Rica, Mexico. He received the “Licenciatura” degree in electronic science, Autonomous University of Puebla (BUAP), México in 2002 and the M.Sc and Ph.D degree in Automatic Control from the Grenoble Institute of Technology and Joseph Fourier University, Grenoble, France, in 2004 and 2008, respectively. Between January and June 2008, he was a Postdoctoral Researcher at GIPSA-Lab Laboratory, Grenoble, France. After spending one year at the University Polytechnic of Puebla, Mexico as an assistant Professor, he joined in June 2009 the Faculty of Electronics, Autonomous University of Puebla, Mexico, where he established and directs the Control and Power systems Laboratory. His research interests include modeling, estimation and nonlinear control of Cyber-Physical Systems. Applications concerns Micro Unmanned Aerial Vehicles (MAVs ) and wearable robots.
Índice de visibilidad digital v1.0 · Mide qué tan completo está el perfil, no la calidad académica. Escala: 0–39 incompleto · 40–79 intermedio · 80–100 completo. ¿Cómo se calcula? · ¿Te falta un dato? Avísanos
Últimas publicaciones Scopus
- 2026
- A New Switching Configuration for a Bipolar Full-Bridge Boost Converter: Dynamic Analysis and Model Validation Electronics Switzerland · Vol. 15 Article
- Trajectory Control for Car-like Mobile Robots via Frugal Predictive Control with Integrated Disturbance Rejection Actuators · Vol. 15 Article
- Contraction-based active disturbance rejection controller for an active ankle foot orthosis Control Engineering Practice · Vol. 169 Article
- Lyapunov-Driven Control Design for Quadrotors with Heading-Velocity Command Inputs: Further Insights Towards a Digital Twin 2026 International Conference on Unmanned Aircraft Systems Icuas 2026 Conference Paper
- Cooperative Control of Multirotor AAVs with Disturbance Rejection Capabilities for Load Transportation IEEE Access · Vol. 14 Article